Research Project 10/2024 – 03/2026
Vibro-Sense
- Tactile Sensing
- Vibro-Acoustic Sensing
- Contact Localization
- Deep Learning
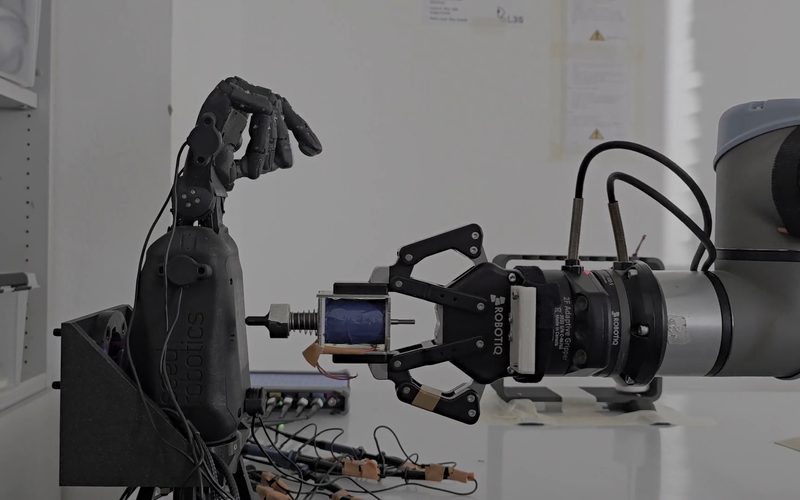
An affordable tactile sensor that senses touch through vibrations, for the robotic hand of the industry partner Nibotics. Funded by the BMBF (DATIpilot), at the L3S Research Center, Leibniz University Hannover.
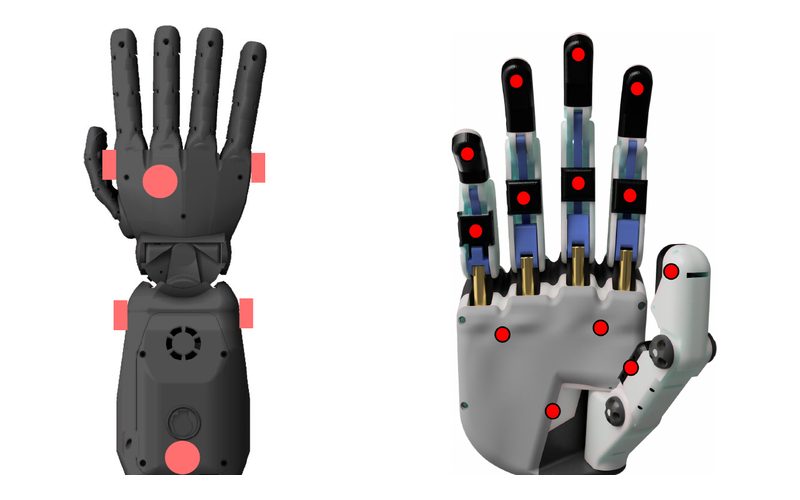
- Touch localization across a whole robotic hand with seven low-cost piezoelectric microphones, with an average error under 5 mm in static conditions.
- Tracking of moving contacts, also while the hand itself moves, telling external contacts apart from the robot’s own vibrations.
- Datasets, models and experimental setups released as open source.
Sources: L3S project page and the papers below.